C05 / Exchangeable mission modules
Many devices. One robot head.
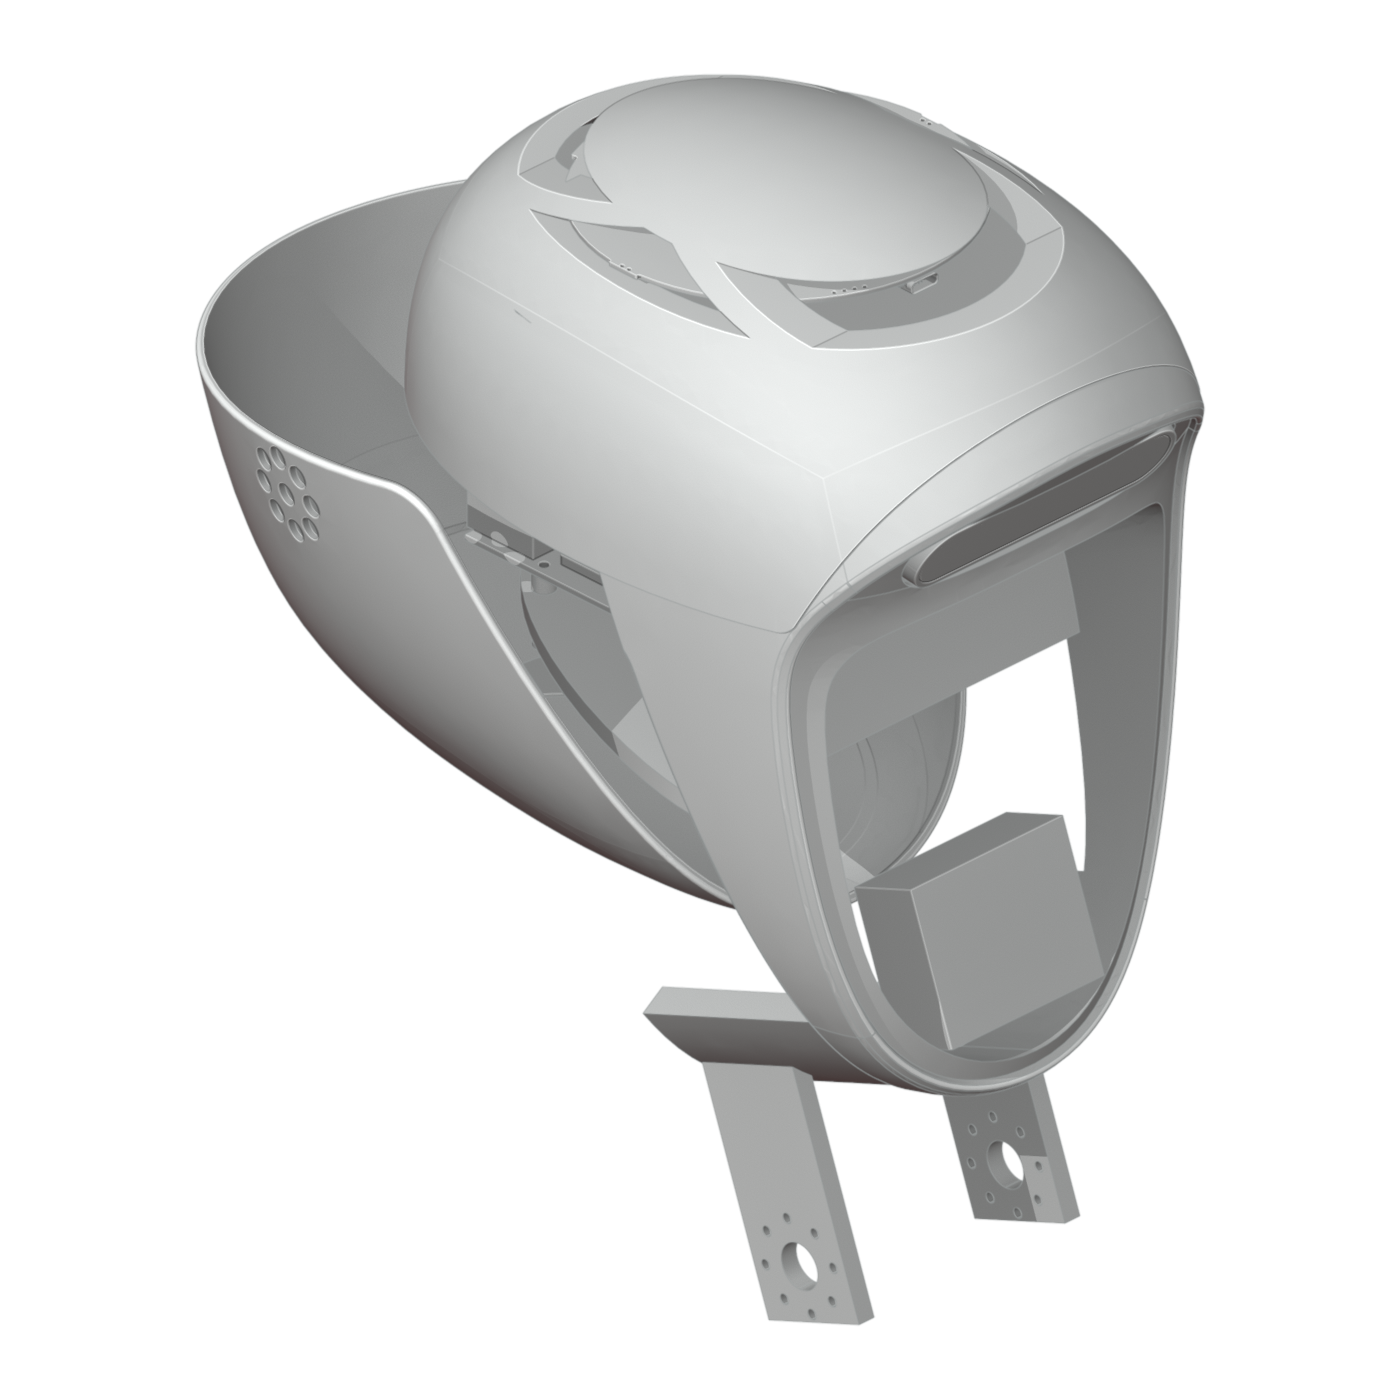
Robot head: device layout and mechanical design
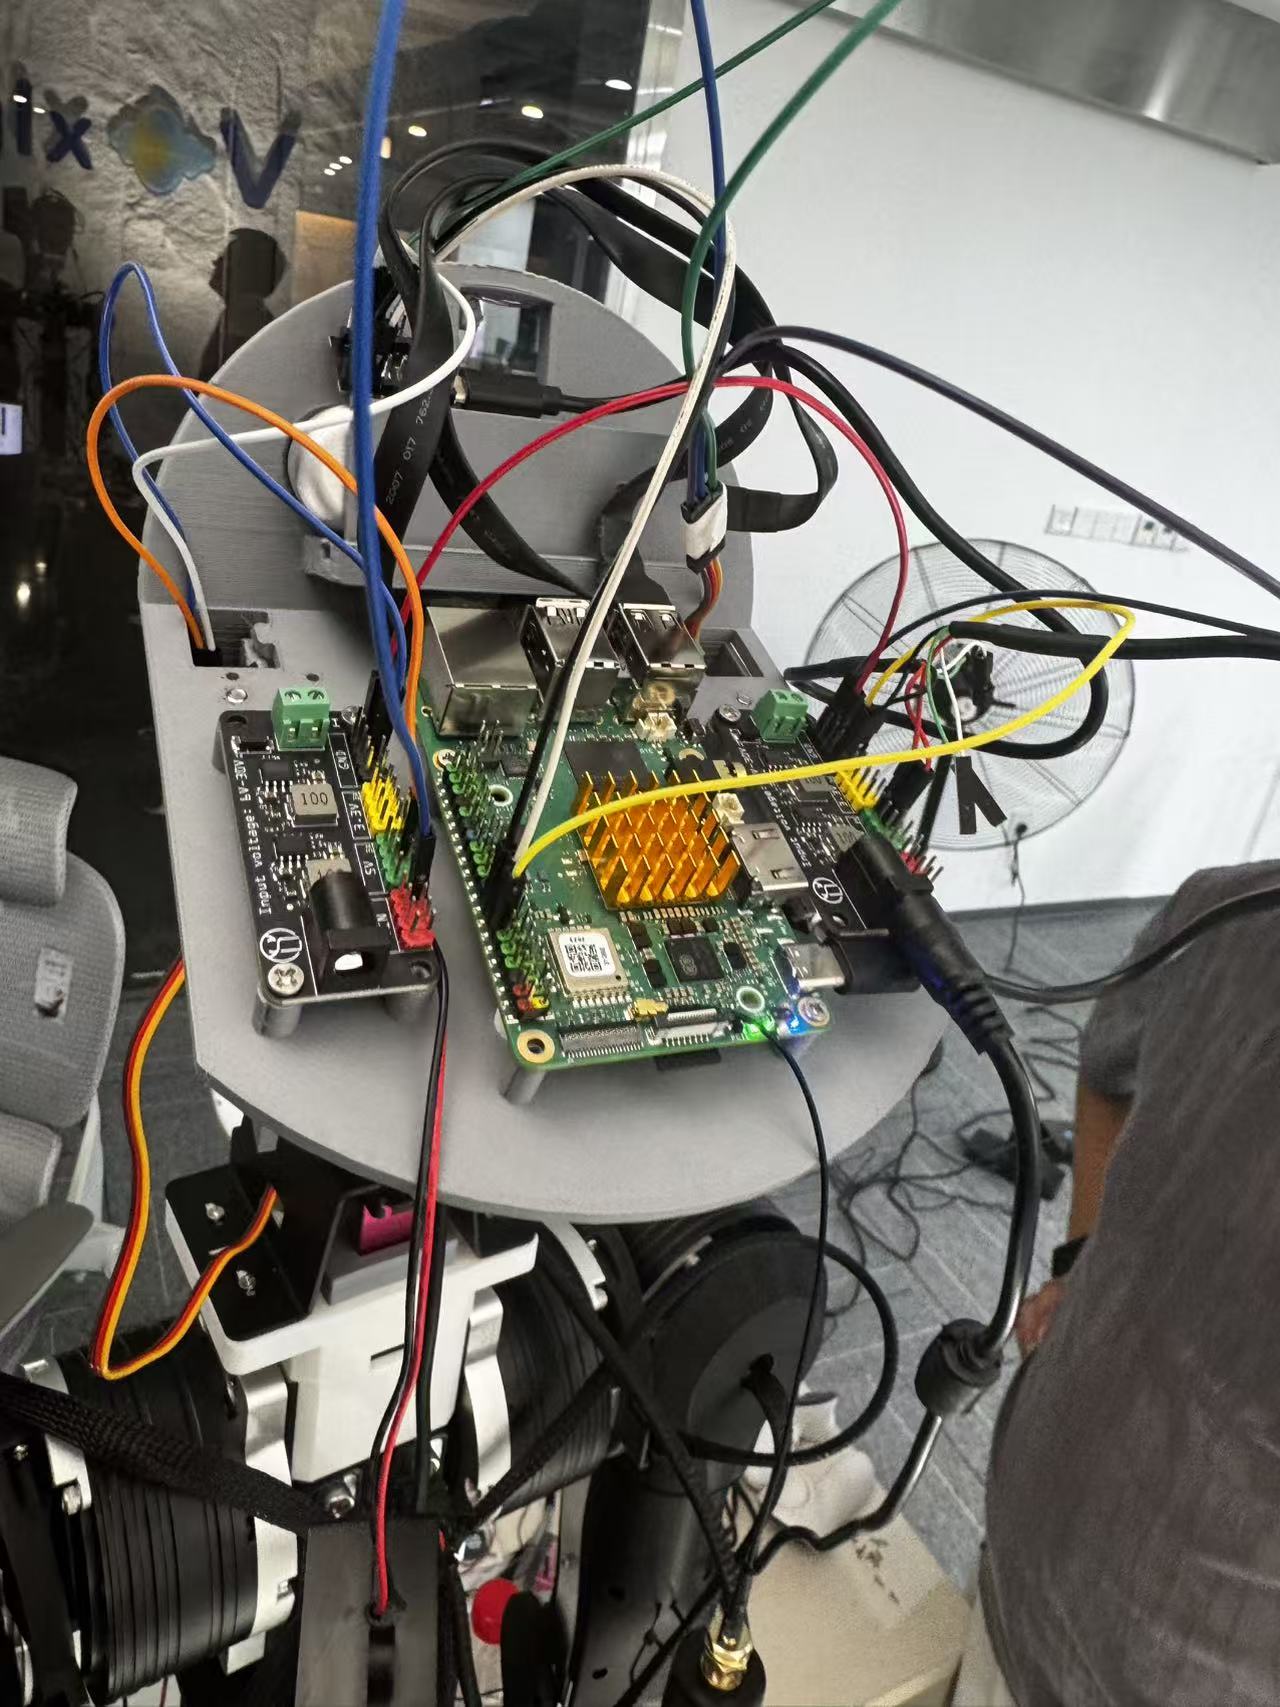
The robot head packs cameras, a display, microphones, computing and power boards, and wiring into a small volume. Device dimensions and mounting relationships guide supports, the internal frame and the enclosure, with each part available for revision.
I consider not only whether a device fits, but how its fasteners are reached, where tools enter and what comes off first. The mainboard, power boards on both sides and expansion board also shape the cable routes and usable space.
Let the structure serve the devices.
Following an audio colleague’s test feedback, I moved the microphone array from the top to below the main structure, added isolation and left its surroundings open. Placement responds to operation as well as appearance.
After changes to the power arrangement, roughly five or six neck cables became one Ethernet cable and two power cables. A smaller expansion board freed further space. I revised supports and assembly relationships around these changes.
ROBOT HEAD / ASSEMBLY
From layout to the physical build.